 |
 |
|
 |
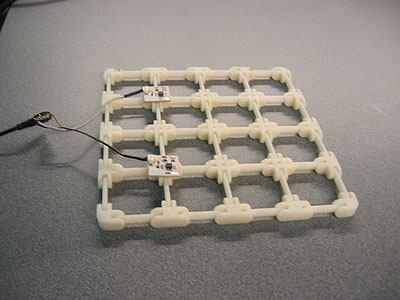
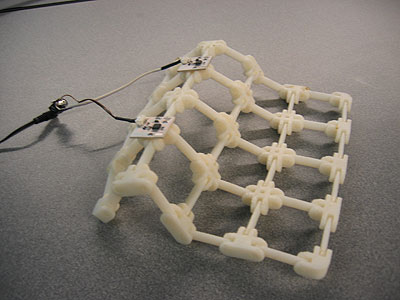
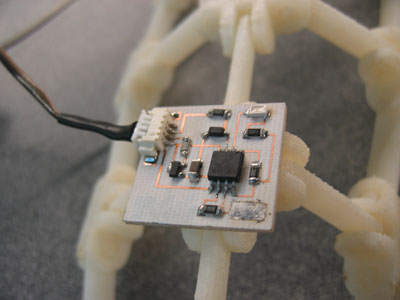
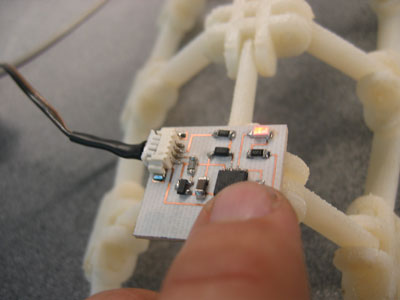
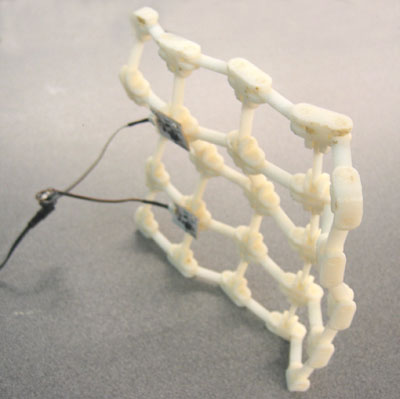
this week's ingredients: another antistatic plastic bag with tiny goodies, some different resistors (which is which), a capacitor, a red LED, a regulator, a zener diode, a serial connection header, but this week we upgraded our boards to the ATtiny15Lmicrocontroller Again the cables played a crucial role on the nightmare of trayibg to program the board. The cables were resolded 3 times. After trying several methods to make the board, specially as we were supposed to try using the Vynil Cutter and the adhesive Copper Film which after cutted and peeled off was to be fixed on an epoxy film. After hours, I abandoned that way and went with the photo-etching process, which in minutes delivered 4 crispy clear boards ready to be assembled. the soldering part of the board was easy this time (practice, practice) and then using a code written by Neil for this EFE Board I UISP the code down to the processor and tryied to activate it. But the star of this assignment was definitevely finding the "B value". I tried for hours, literrally. I almost quit. There should be an easier way of doing this, apparently with an external oscillator...... Finally It worked, and to complete the assignment, we worked together with Ajah, and combined both boards on my articulated structure, simulating its future hability to both sense movement around it and react, in this case by lightining the path of the movement. Well , by blinking the red LEDs we were given this time.. The boerd worked great, although the sensors aren't sensitive enough to allow some distance to them, but the whole principle was realized, and we are already thinking on different proximity sensors.
distance between contours 0.364 width base 0.244 aluminum sheet size & width 0.127 0.79 x 0.13 |
|
 |
|
 |
|